Robotic gripper fingersAT-067 · One piece
We confirm feasibility after reviewing the sample or drawing.
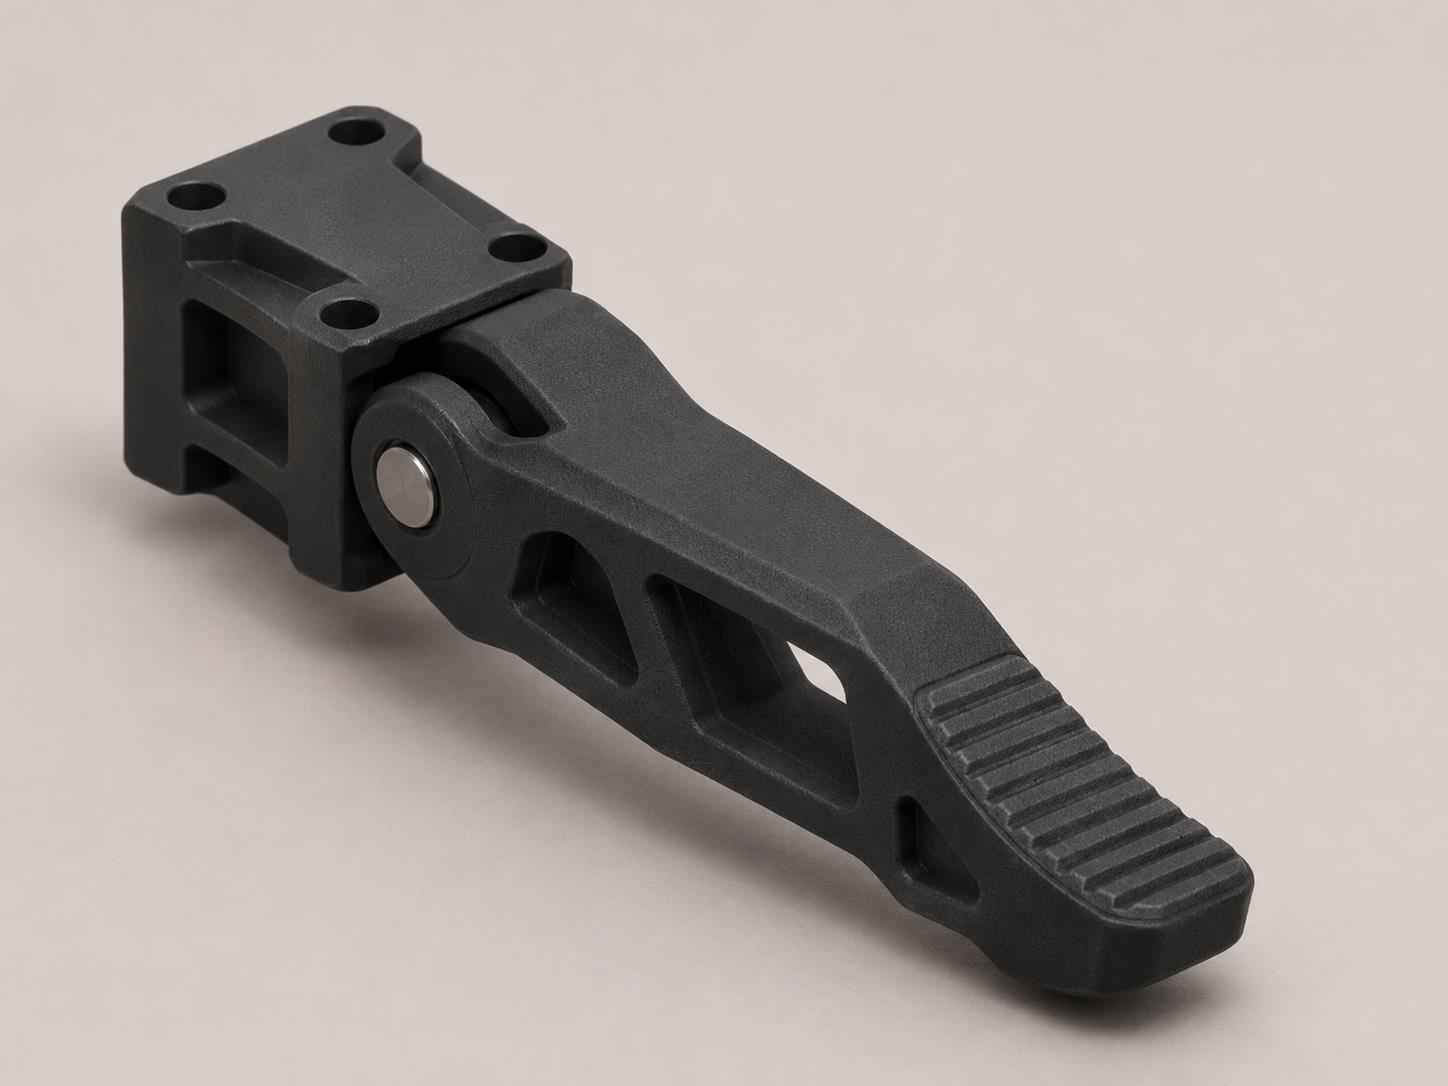
Gripper fingers contact the workpiece, follow its contour and hold it while the robot moves it.
Robotic end-effector contact tipsAT-068 · One piece
We confirm feasibility after reviewing the sample or drawing.
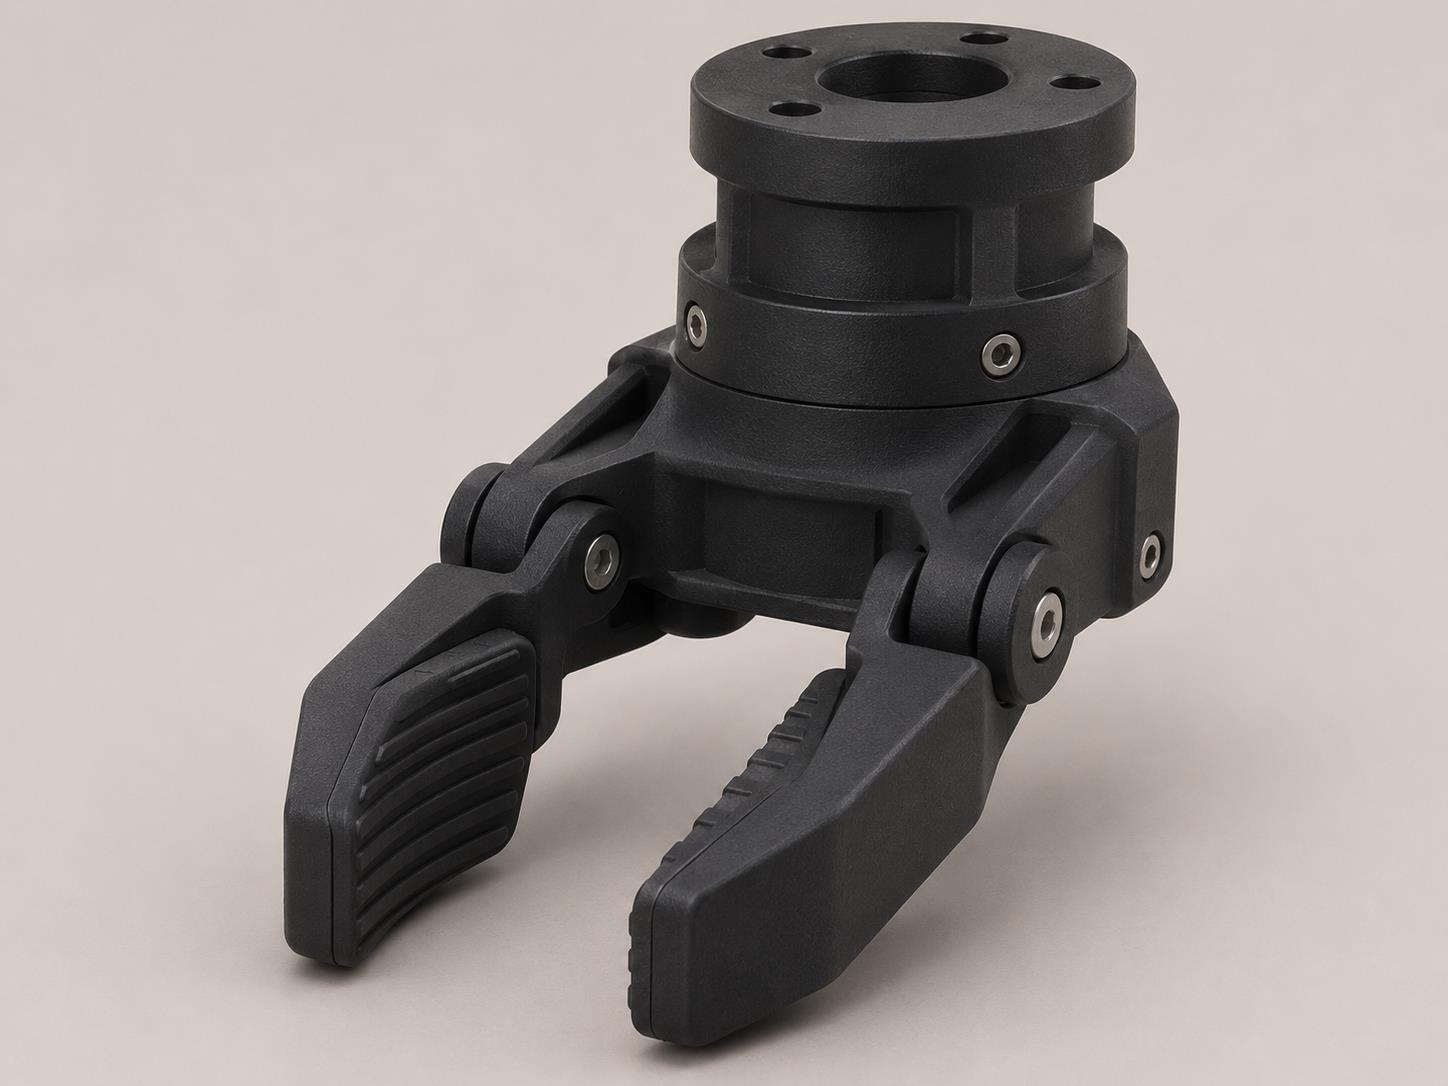
The contact tip defines where the gripper bears on the workpiece and distributes pressure at that point.
Robotic linkagesAT-069 · One piece
We confirm feasibility after reviewing the sample or drawing.
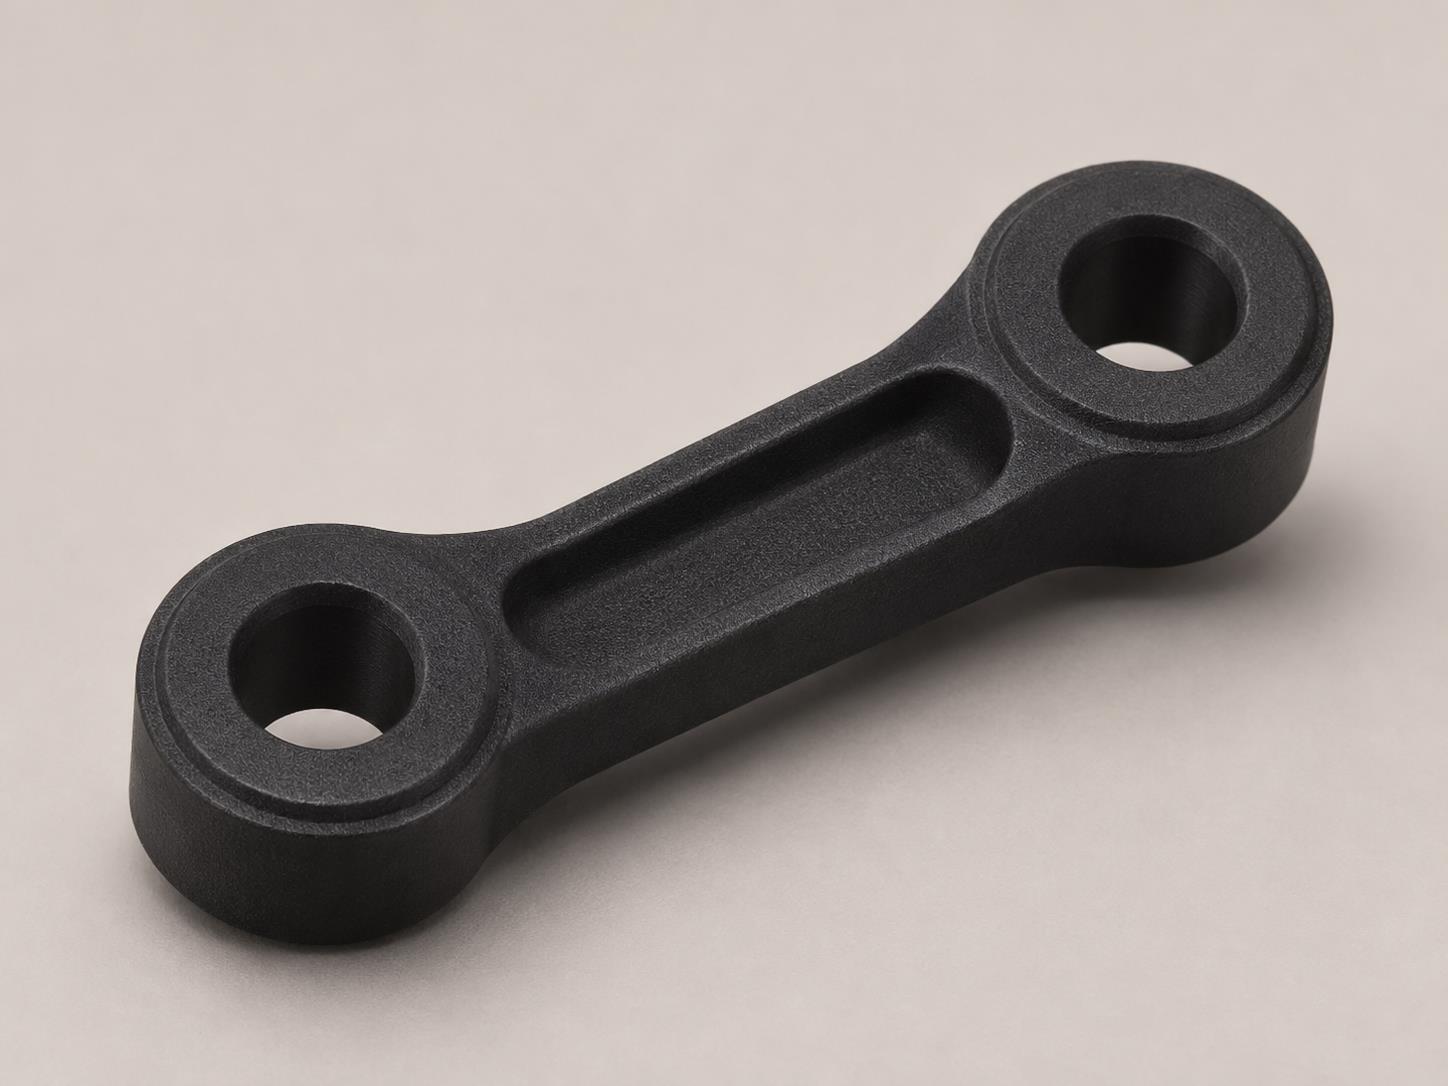
The linkage joins two pivots and transfers motion between them.
Custom brackets and mountsAT-070 · One piece
We confirm feasibility after reviewing the sample or drawing.
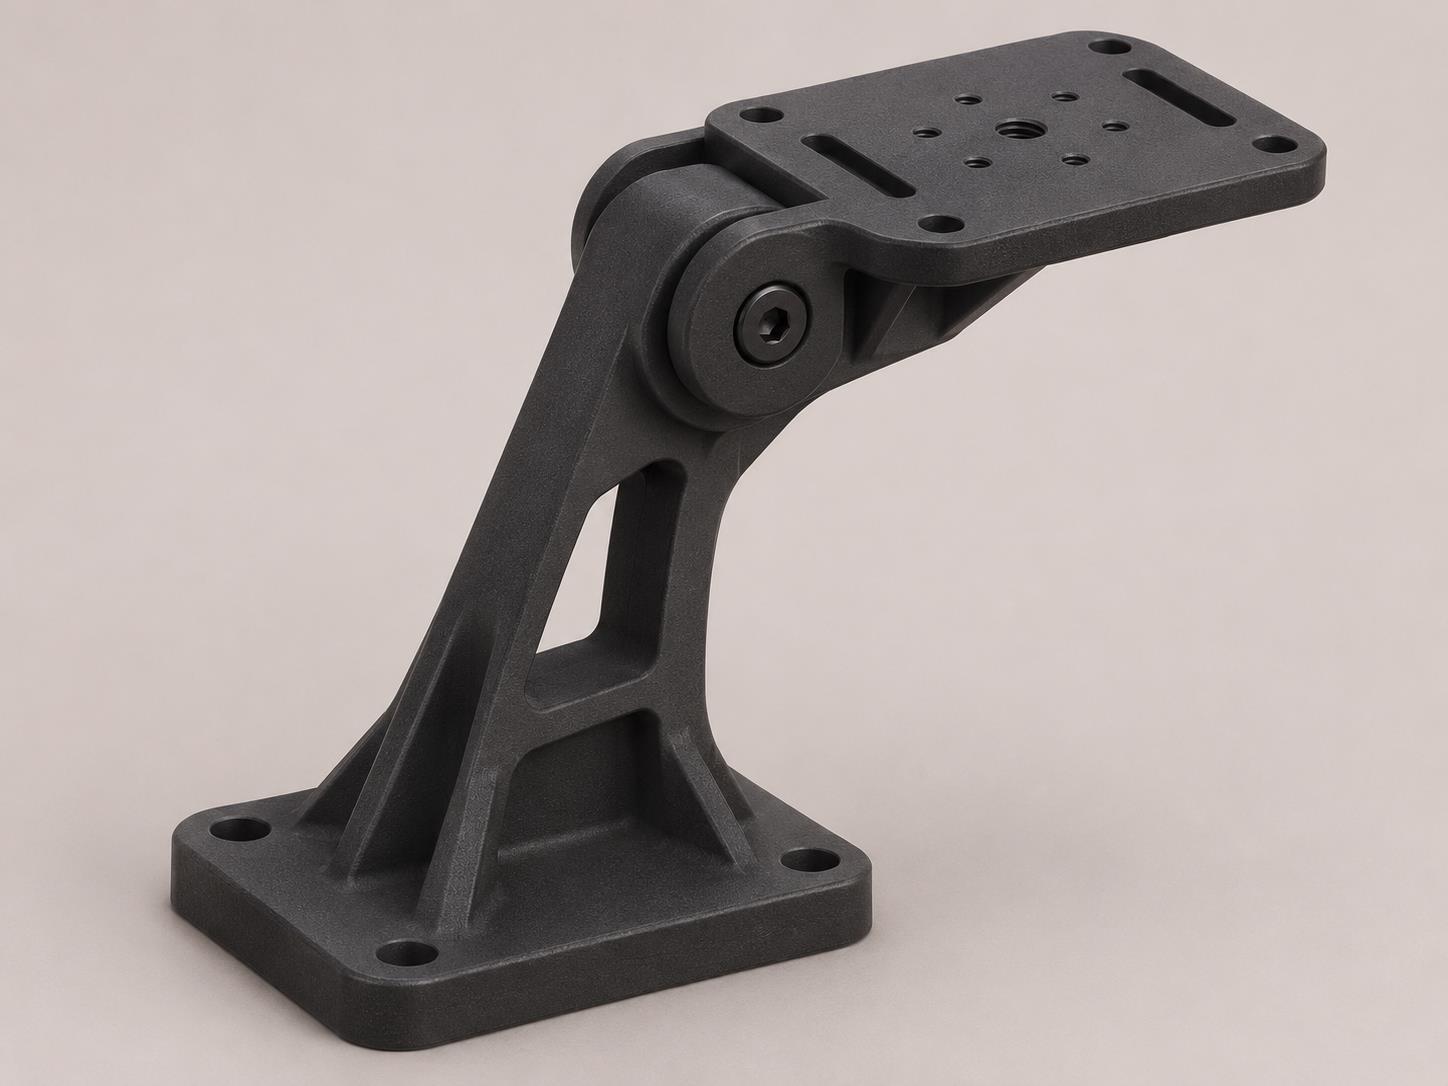
The mount holds a machine-vision camera at the position and angle needed to see the station.
Custom brackets and mountsAT-071 · One piece
We confirm feasibility after reviewing the sample or drawing.
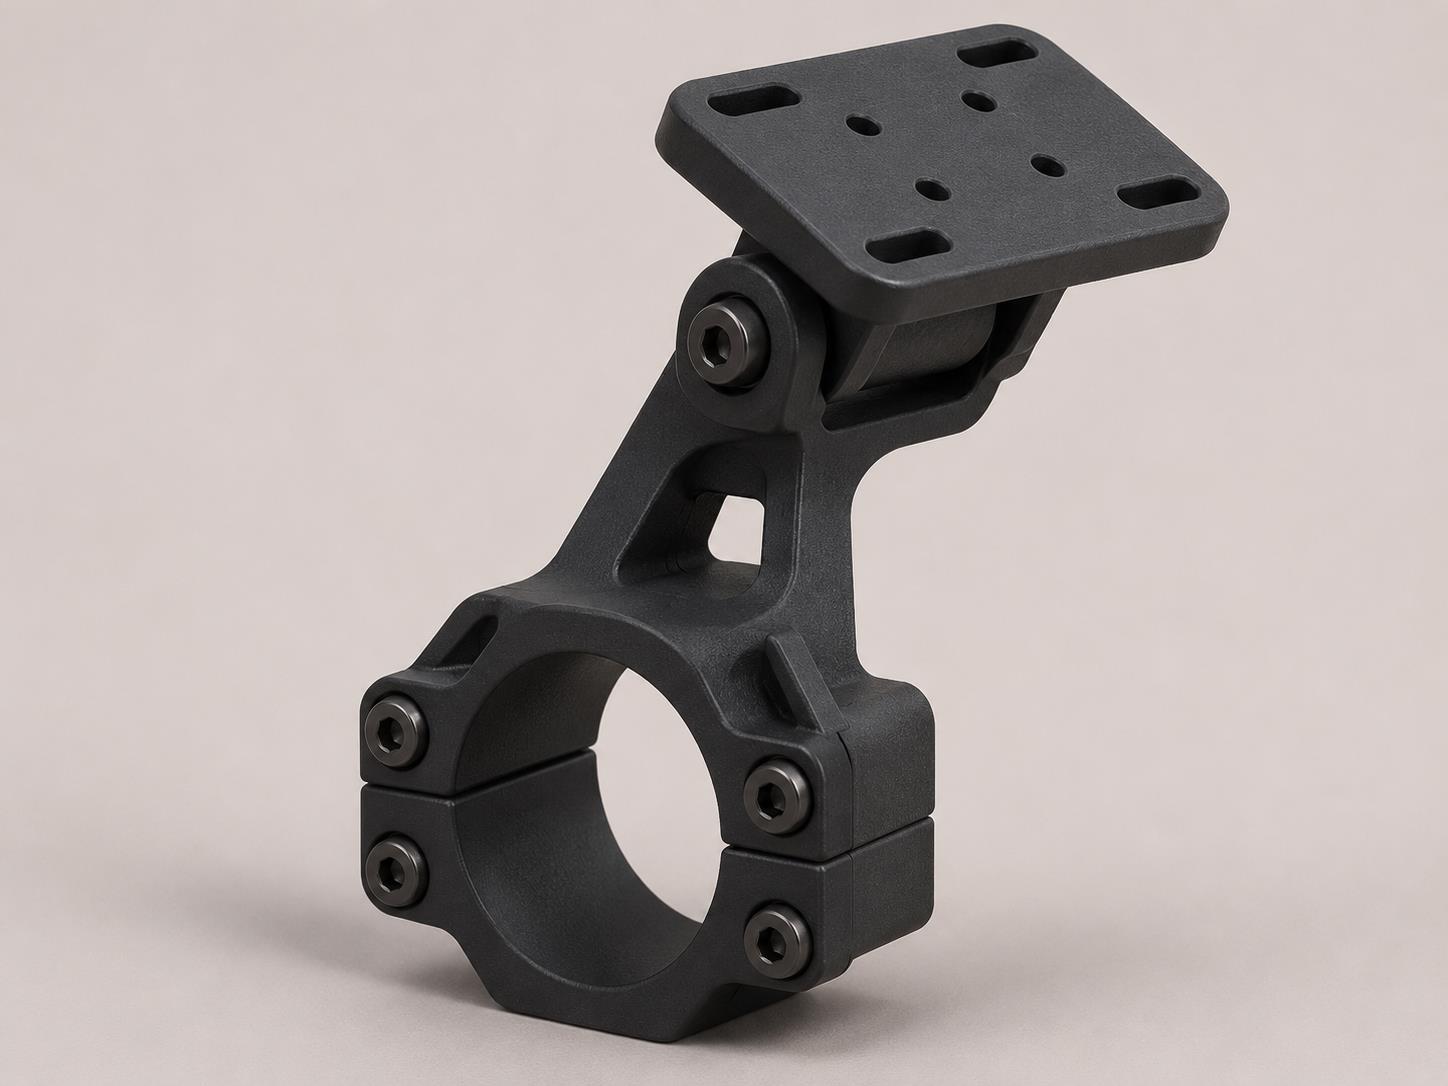
The mount locates a sensor next to its detection zone and helps restore its position after adjustment.
Custom electronics enclosuresAT-072 · One piece
We confirm feasibility after reviewing the sample or drawing.
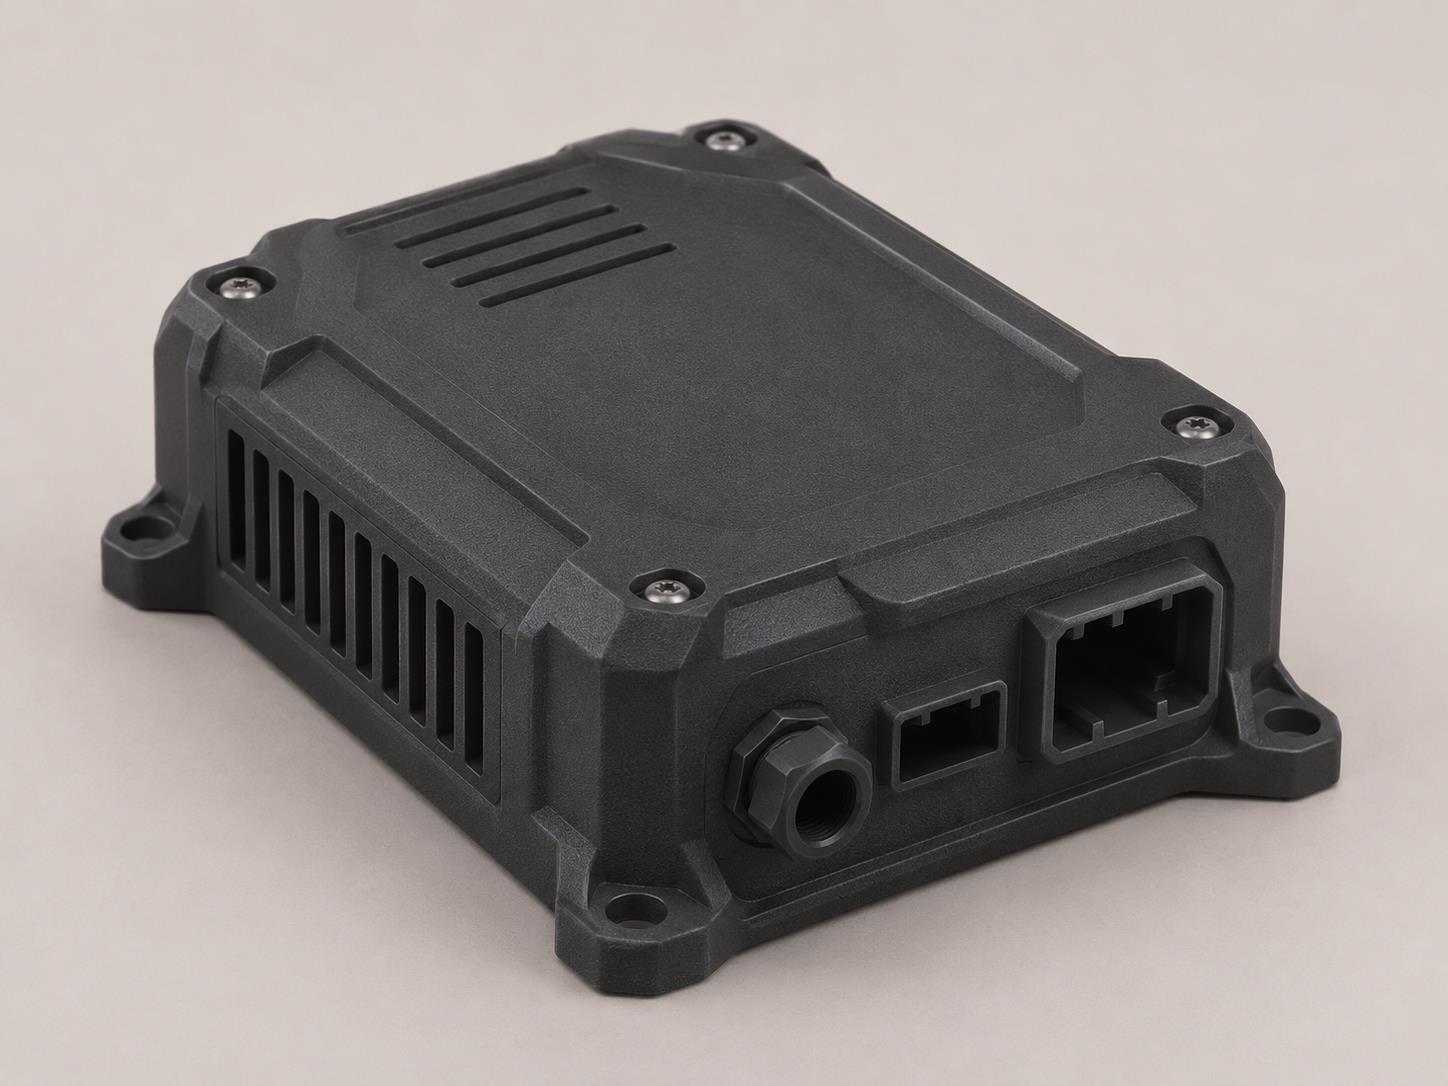
The enclosure houses the automation controller and organises access to its wiring.
Custom brackets and mountsAT-073 · One piece
We confirm feasibility after reviewing the sample or drawing.
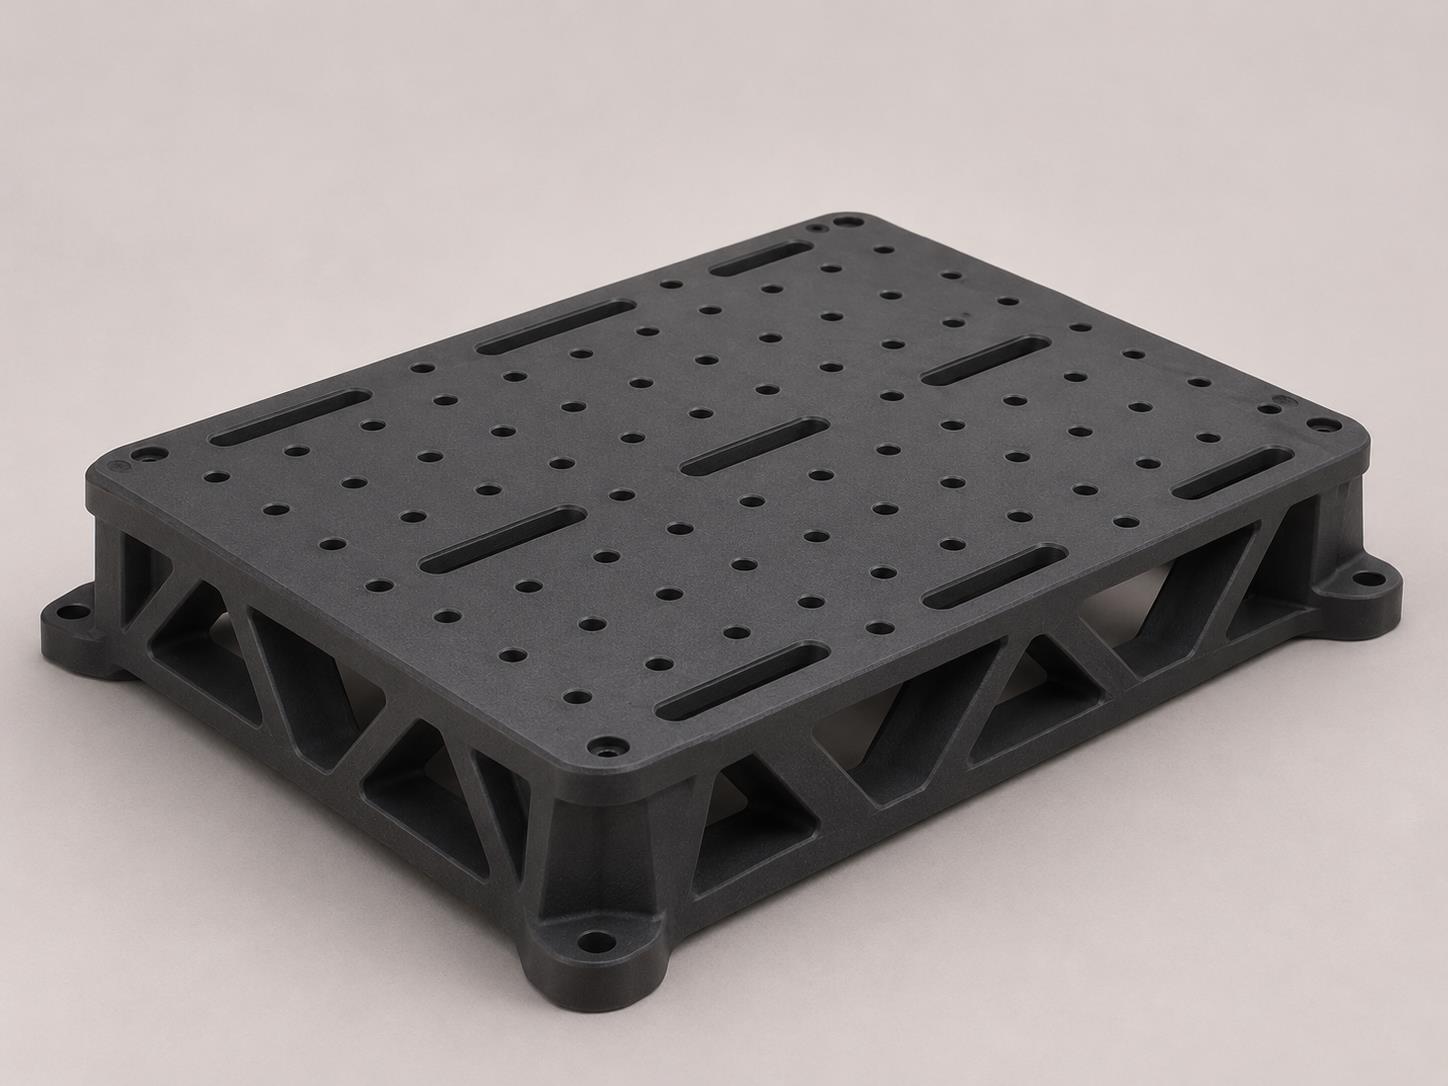
The platform provides a shared mounting surface for placing modules in repeatable positions.
Custom brackets and mountsAT-074 · One piece
We confirm feasibility after reviewing the sample or drawing.
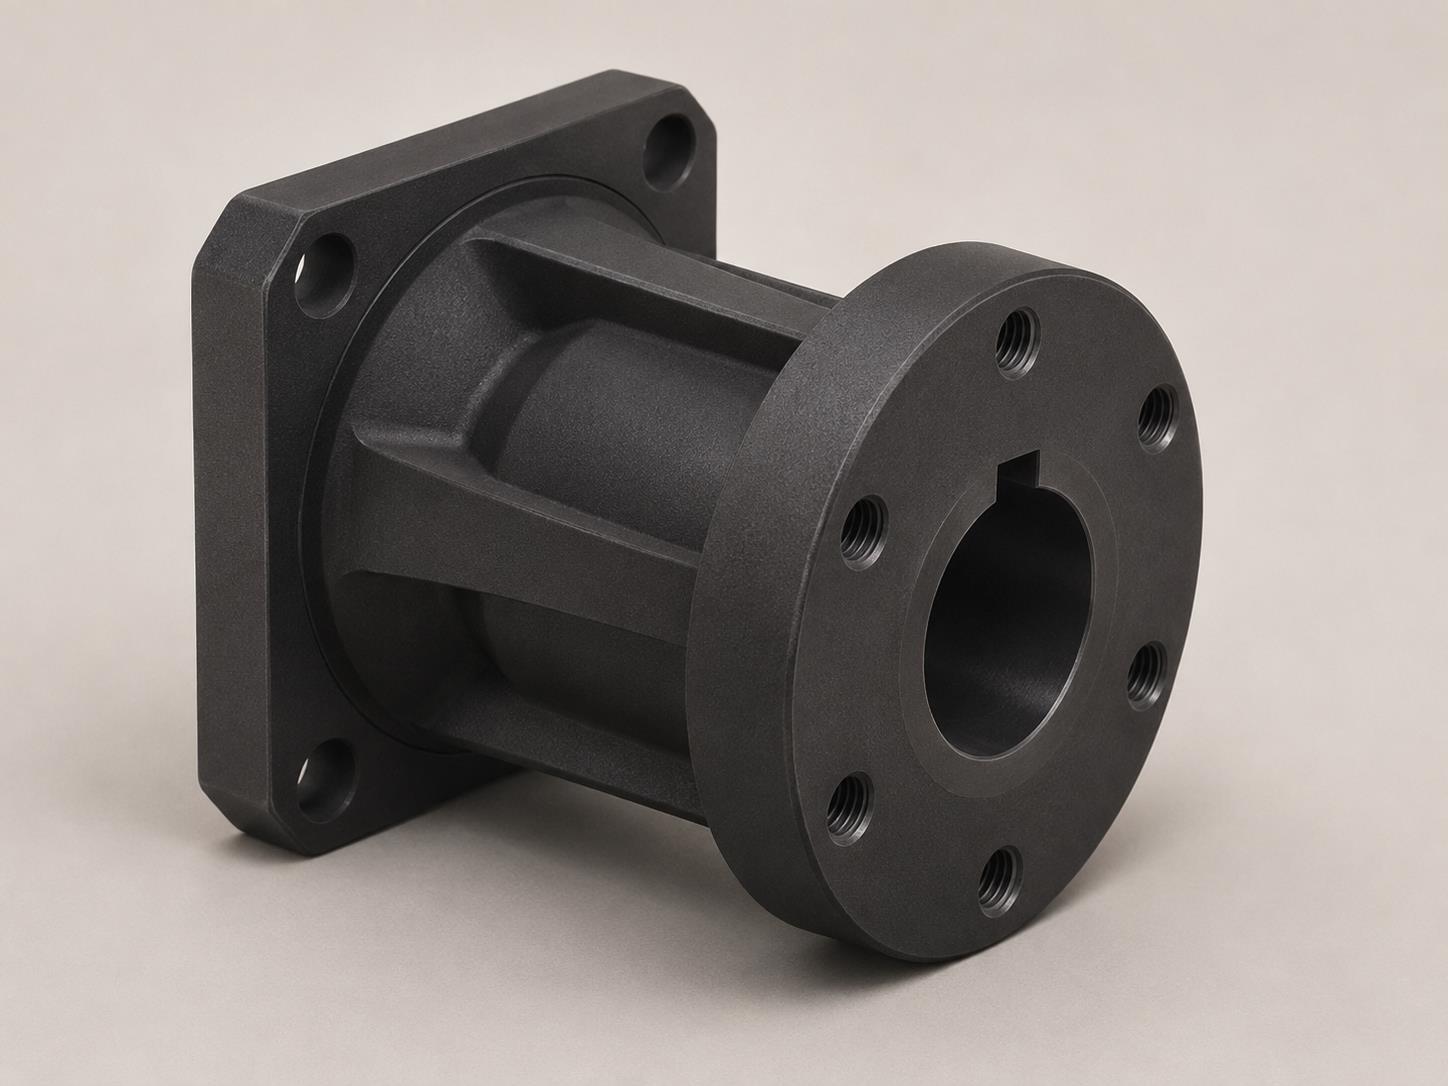
The adapter helps check how an actuator fits an assembly with a different mounting interface.
Cable guides and supportsAT-075 · One piece
We confirm feasibility after reviewing the sample or drawing.
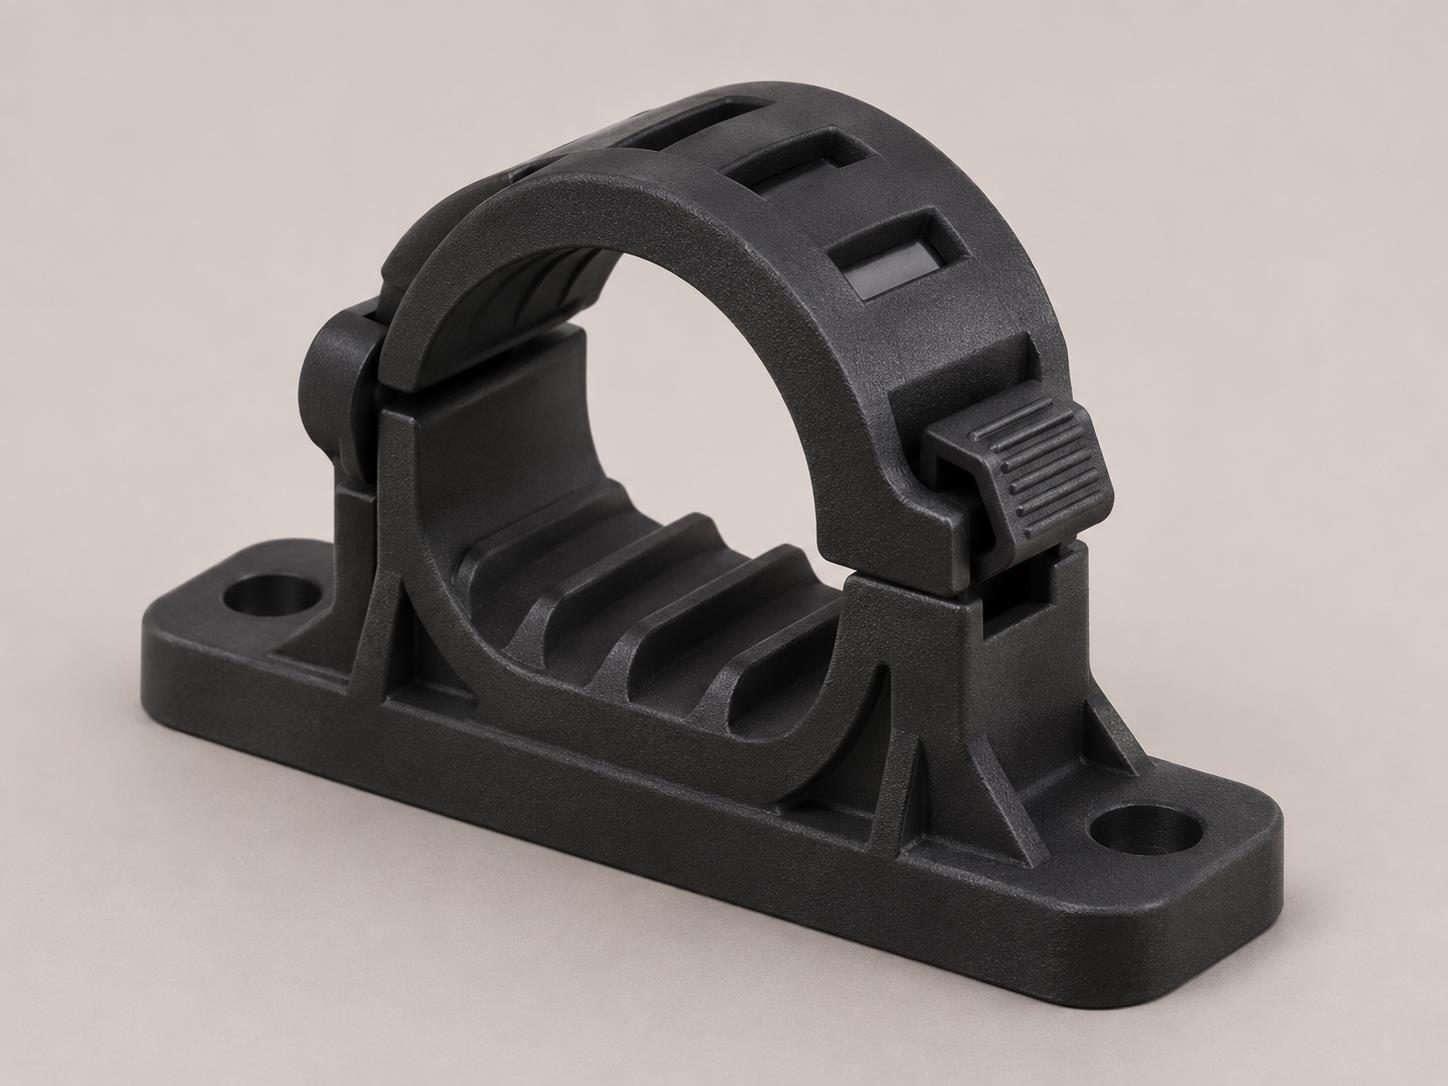
The holder routes the harness along the station and keeps it outside the mechanisms’ path.
Technical spacers and bushingsAT-076 · One piece
We confirm feasibility after reviewing the sample or drawing.
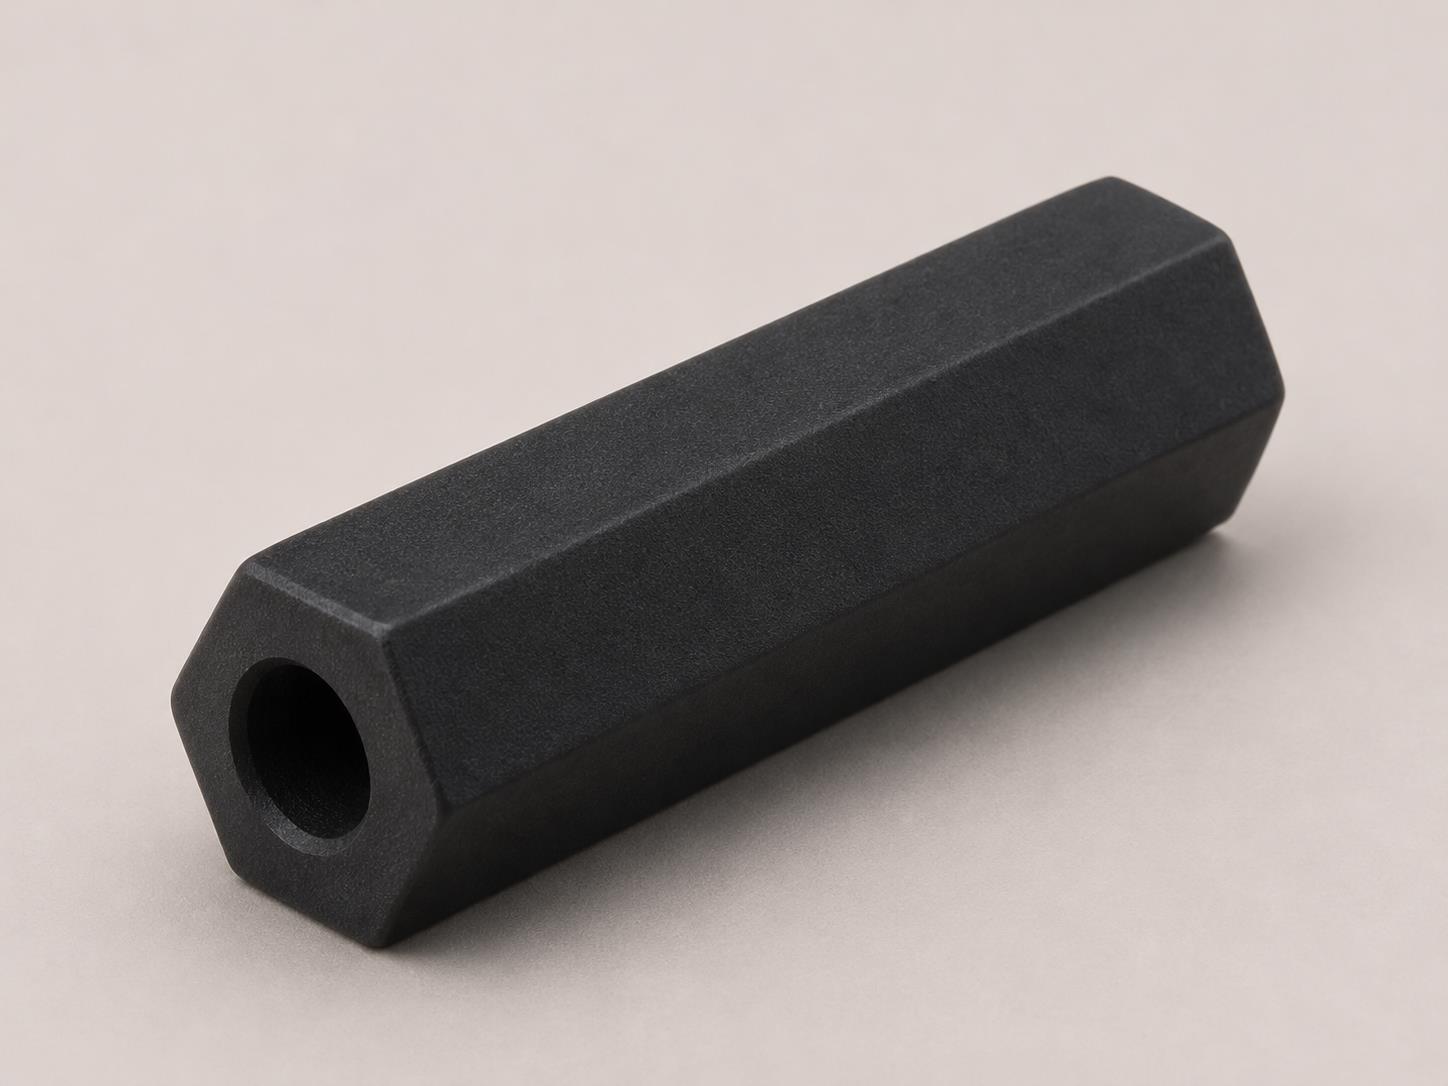
The sleeve spaces two surfaces apart to maintain the intended assembly clearance.
Robotic linkagesAT-077 · One piece
We confirm feasibility after reviewing the sample or drawing.
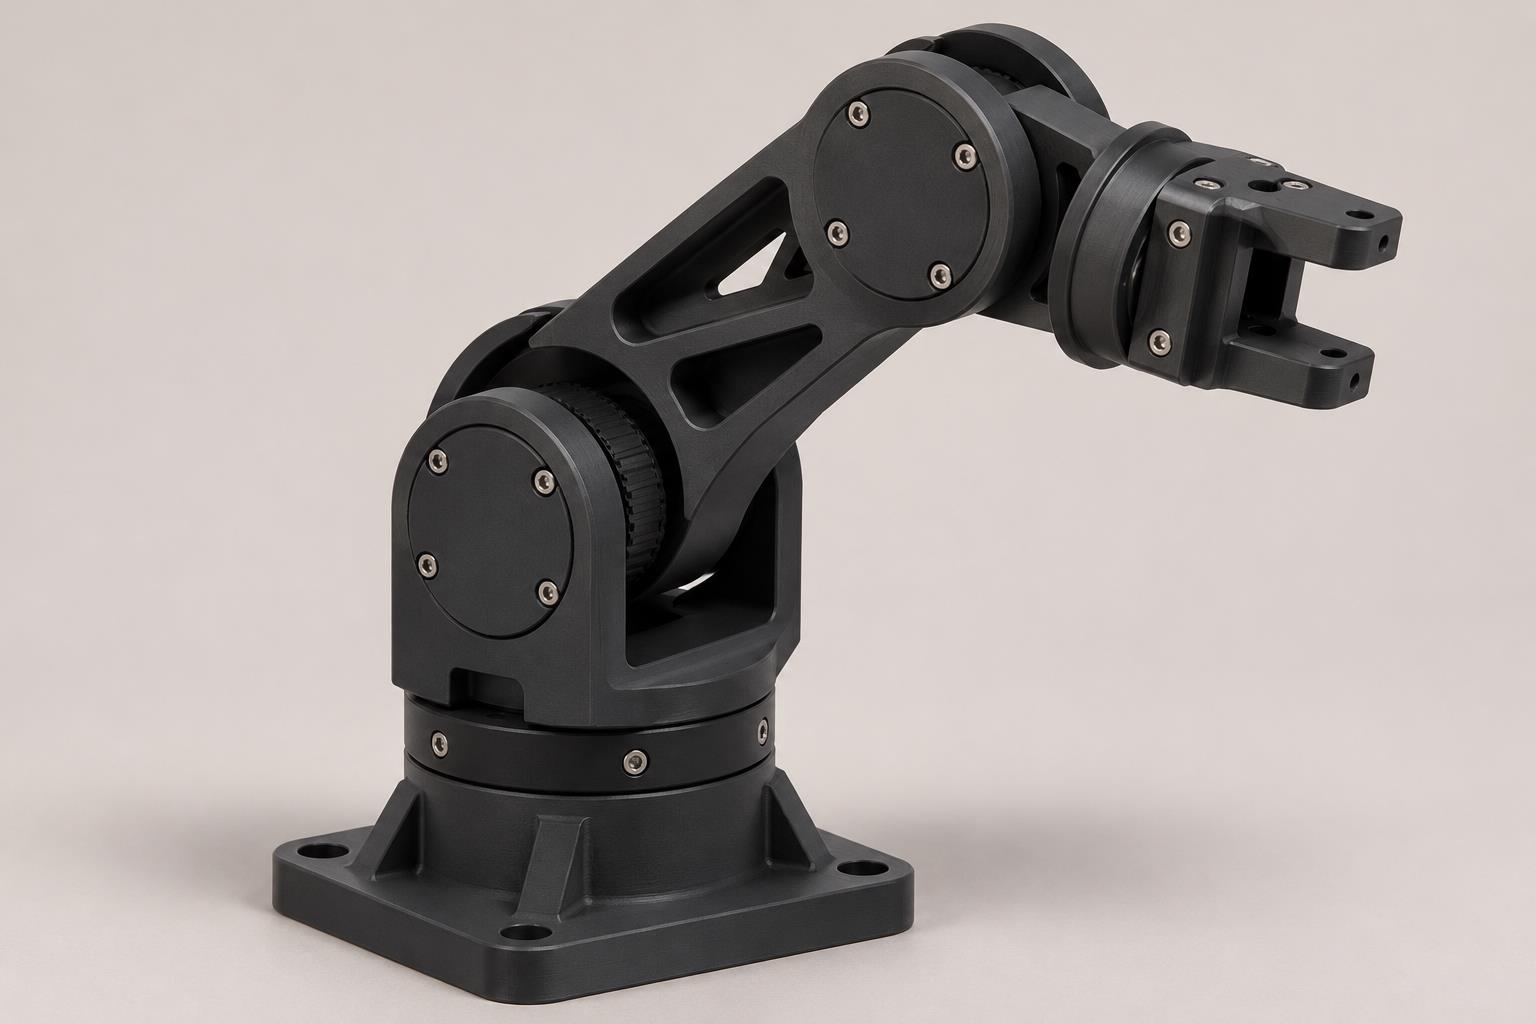
A moving prototype reveals travel and potential interference before the final part is defined.
Non-structural machine coversAT-078 · Segmented
We confirm feasibility after reviewing the sample or drawing.
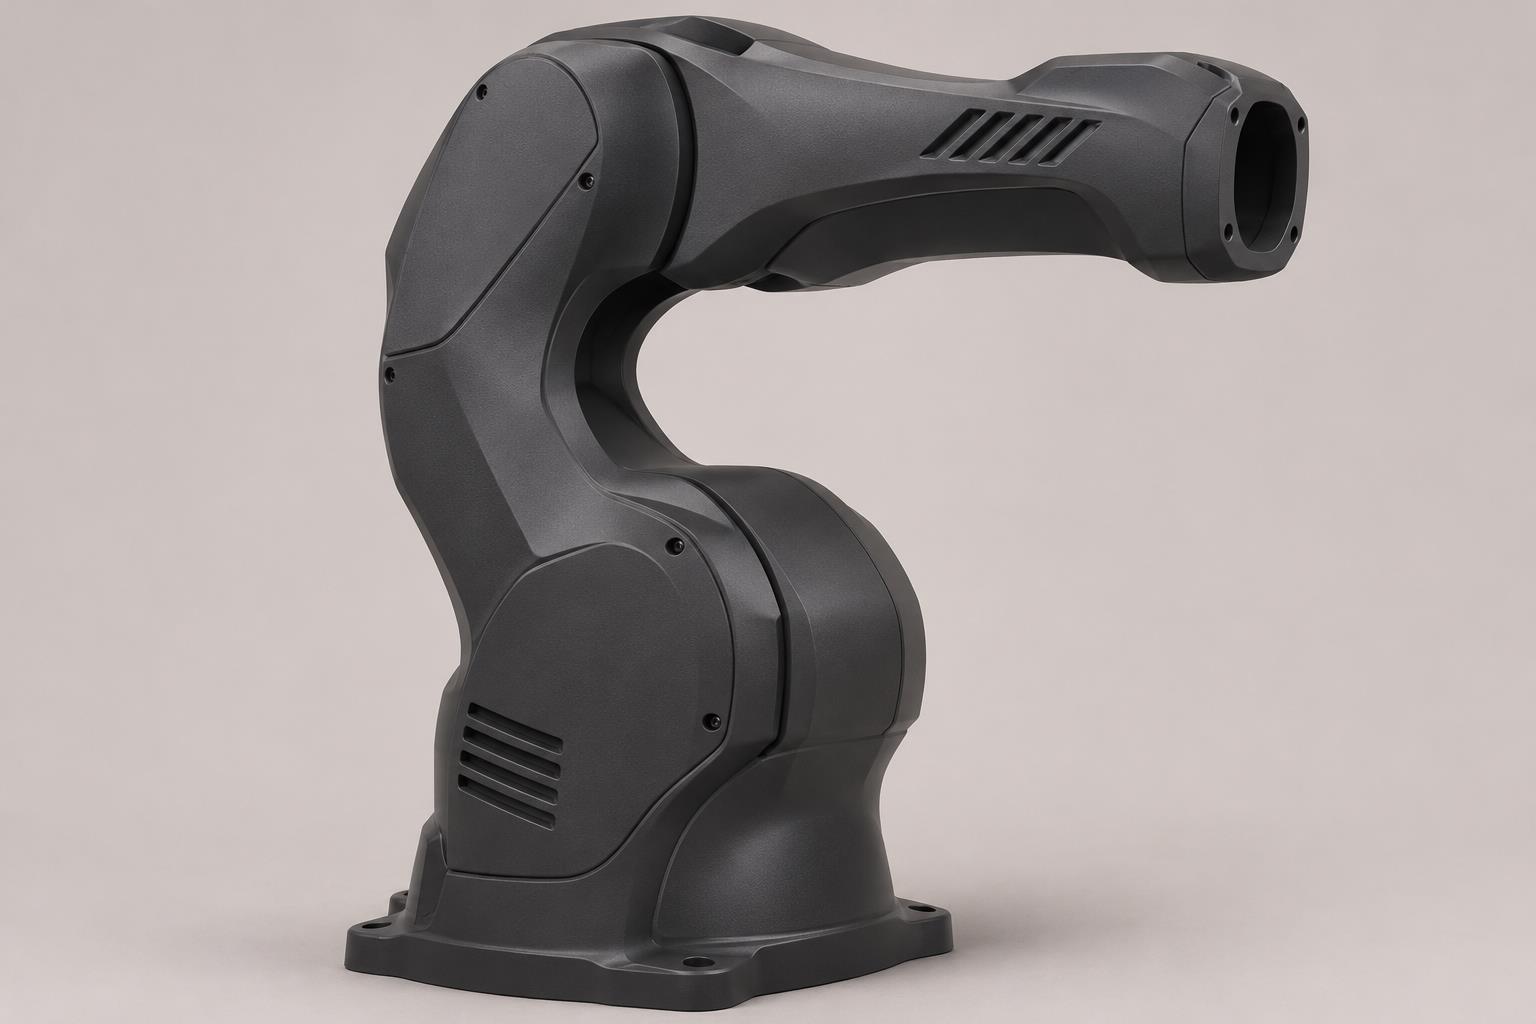
The decorative shell finishes the robot’s exterior and conceals auxiliary components.
Non-structural machine coversAT-079 · Segmented
We confirm feasibility after reviewing the sample or drawing.
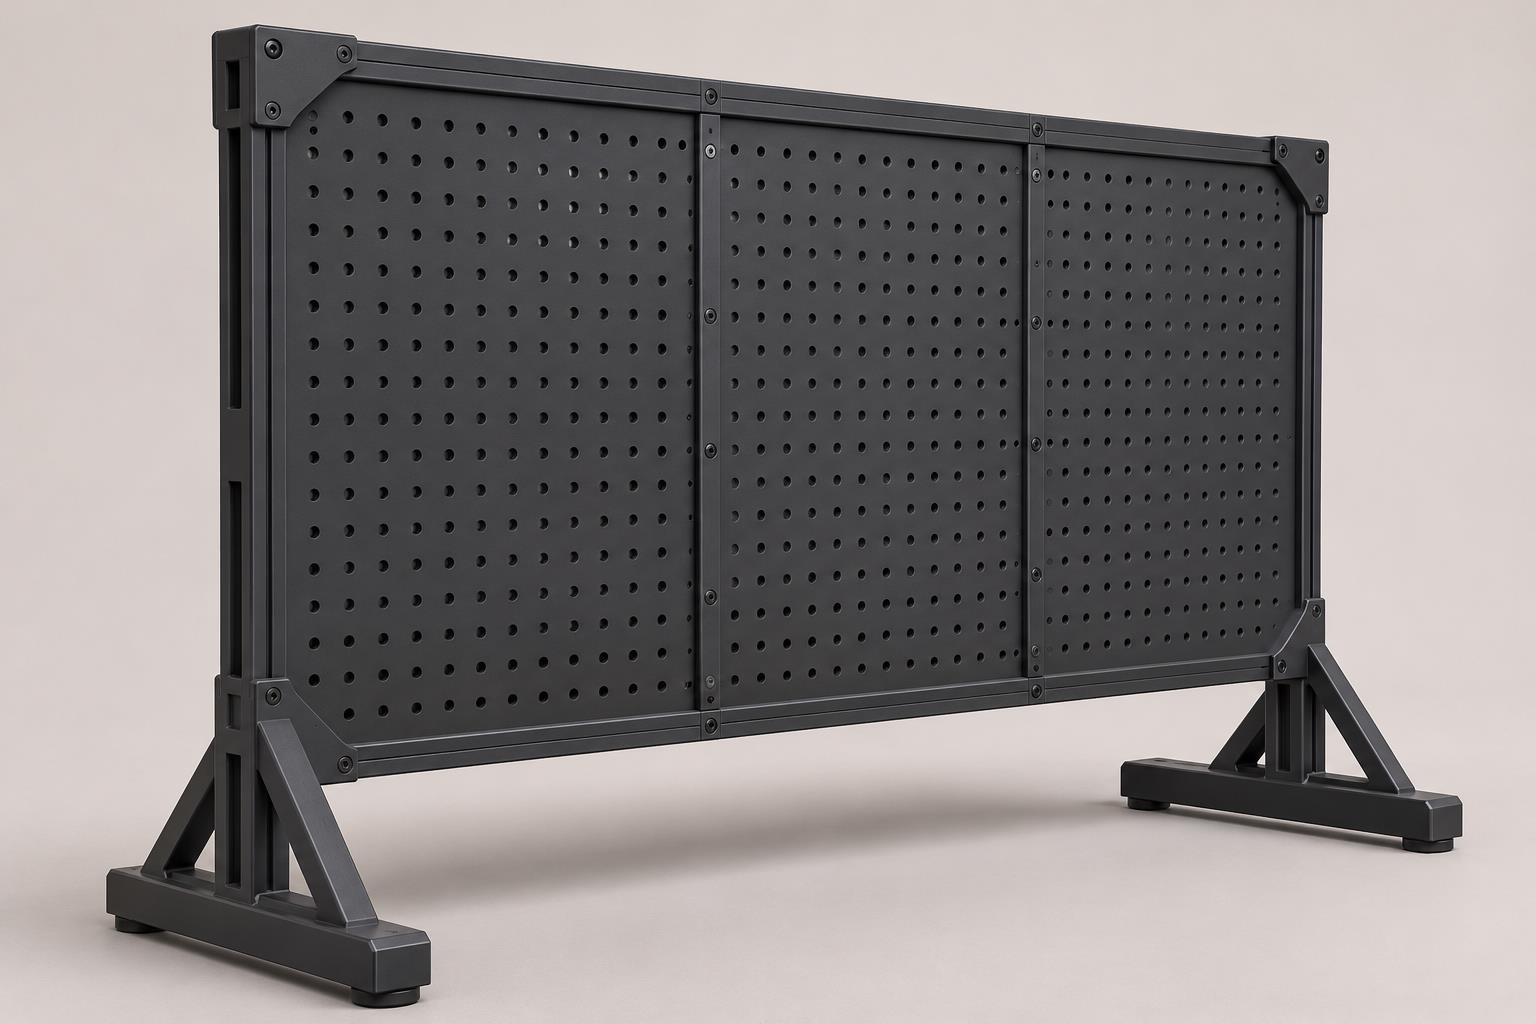
The non-structural panel closes off a face of a robotics test stand and can provide openings for controls or connections.