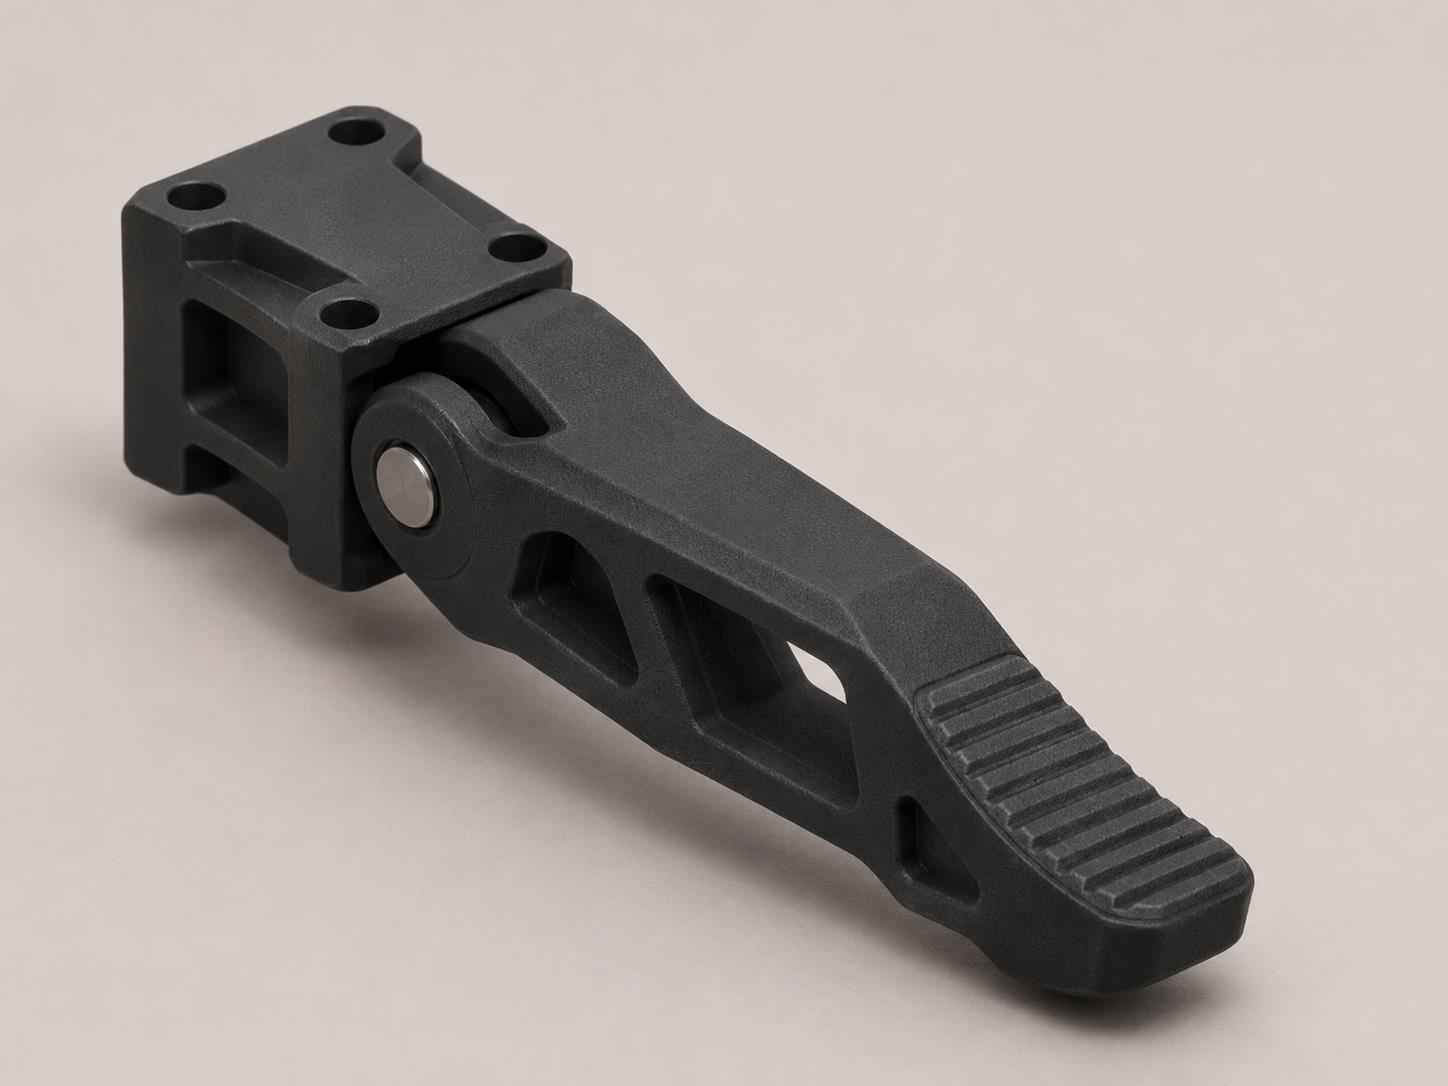
Gripper fingers shaped for the workpiece a robot handles.
We confirm feasibility after reviewing the sample or drawing.
Review contact zones, jaw travel and the risk of marking the workpiece.
AT-067 · One piece
Gripper fingers contact the workpiece, follow its contour and hold it while the robot moves it.
Provide the gripper model, workpiece mass and duty cycle.